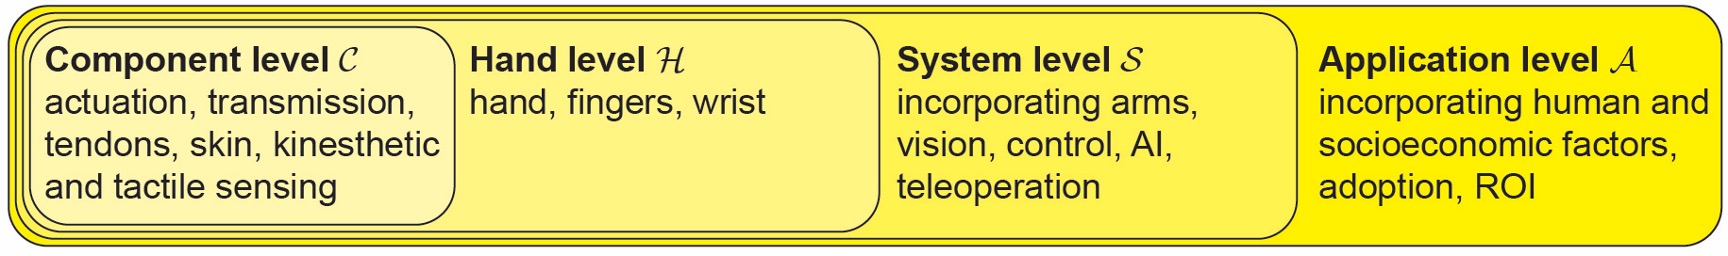
Since robot hands are highly complex systems, we benchmark them at four levels based on the complexity of the system under test. Benchmarks for robot hands serve two purposes:
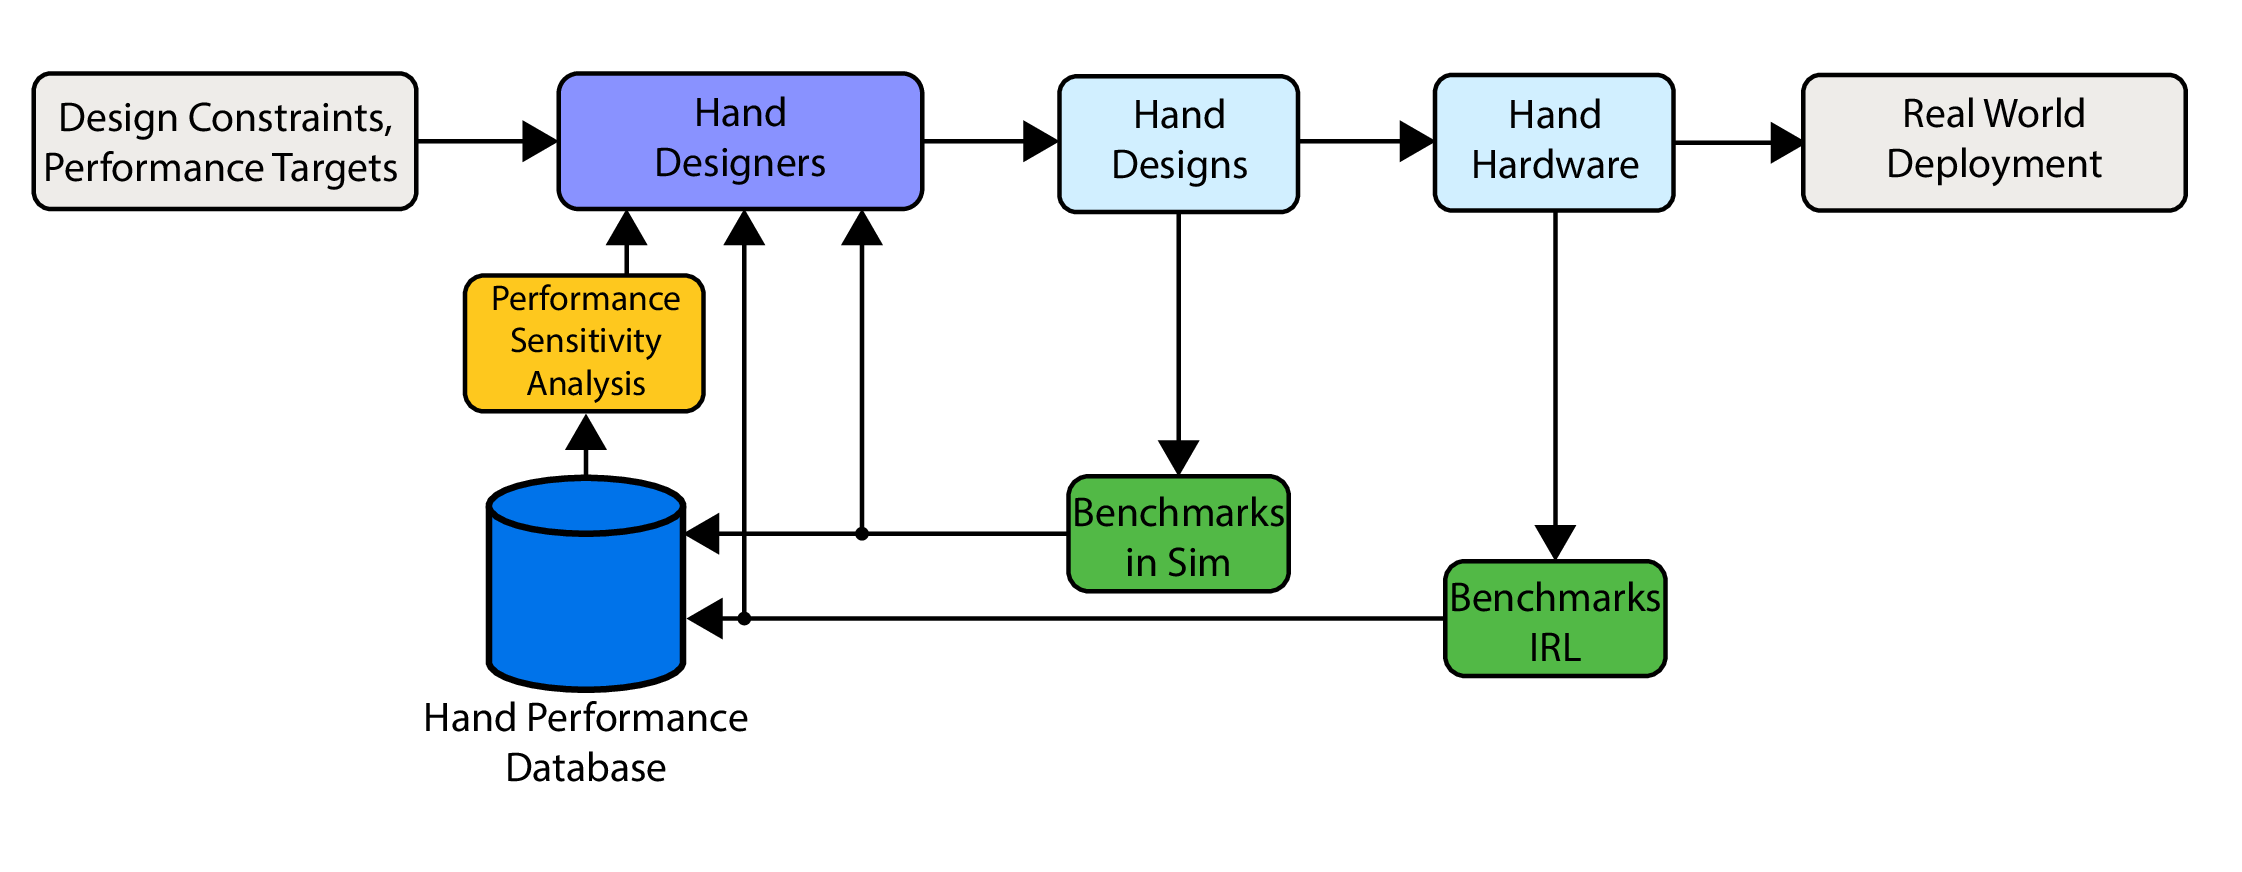
Performance, evaluated using benchmarks in simulation and real-world testing, can provide direct feedback to hand designers. Feedback can also be used in the design process through performance sensitivity analysis to understand how design choices at the component level affect system-level dexterity.